Learning to swim fast with deep reinforcement learning
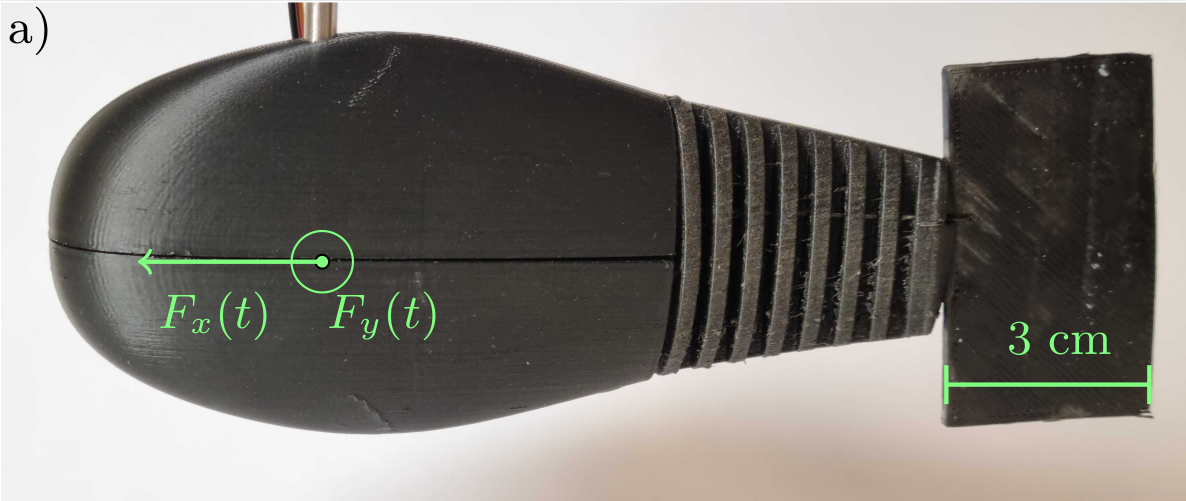
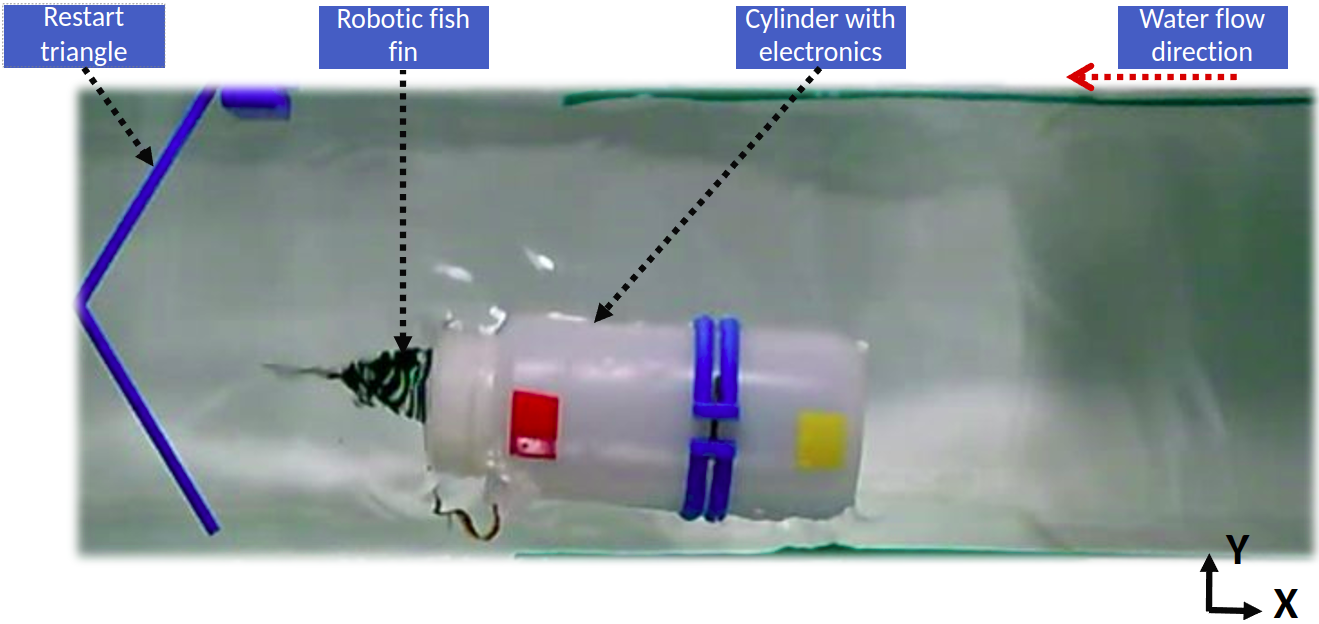
A deep RL agent optimizes the swimming gait of a robotic fish from a camera, force sensors, an IMU and a Raspberry Pi, first in simulation and then on the real robot.
- Visual servoing with a VAE coupled to deep RL.
- Speed and thrust optimization of an autonomous fish.
- Simulation with Gym, MuJoCo and COMSOL, plus real experiments.
Python · PyTorch · Gym · MuJoCo · COMSOL · OpenCV